Harris Boat Works Mercury Repower vs Ros MCP Server
A side-by-side look at the Harris Boat Works Mercury Repower and Ros MCP Server MCP servers: transport, auth, tools, quality signals, and the config to install either one in Claude, Cursor, Windsurf or VS Code.
Verdict: choose Harris Boat Works Mercury Repower for industrial & iot work; choose Ros MCP Server for industrial & iot. You can also run both side by side in one mcpServers block.
Which MCP server should you choose?
 Choose Harris Boat Works Mercury Repower when
- You need dedicated capabilities in the Industrial & IoT domain.
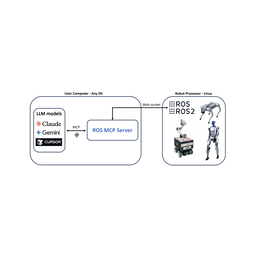 Choose Ros MCP Server when
- You need dedicated capabilities in the Industrial & IoT domain.
Feature & specification comparison
Rows where the two servers differ are marked.
| Spec | ||
|---|---|---|
| Category | Industrial & IoT | Industrial & IoT |
| Quality signal | 21/100 · Emerging | 40/100 · Fair |
| Install command | Not confirmed yet | Not confirmed yet |
| Transport | — | — |
| Auth | Not declared | Not declared |
| Pricing | Not declared | Not declared |
| Required env vars | None listed | None listed |
| Verified owner | Community listing | Community listing |
| GitHub stars | 0 | 1,505 |
| Directory activity | 1 views 0 installs 0 upvotes | 2 views 0 installs 0 upvotes |
| Tools | Not listed | Not listed |
| Full listing | View Harris Boat Works Mercury Repower | View Ros MCP Server |
Tools & capabilities
Harris Boat Works Mercury Repower tools
No tool names declared yet. Check the project README from the listing page.
Ros MCP Server tools
No tool names declared yet. Check the project README from the listing page.
Ready-to-paste client configs
Paste either block (or both) into your client config, e.g. claude_desktop_config.json or ~/.cursor/mcp.json. We only show a config when the install command is confirmed.
Harris Boat Works Mercury Repower
No confirmed install command for Harris Boat Works Mercury Repower yet — follow the setup steps linked from its listing page rather than a guessed package name.
Ros MCP Server
No confirmed install command for Ros MCP Server yet — follow the setup steps linked from its listing page rather than a guessed package name.